Academic
TerraTrek Mars Rover
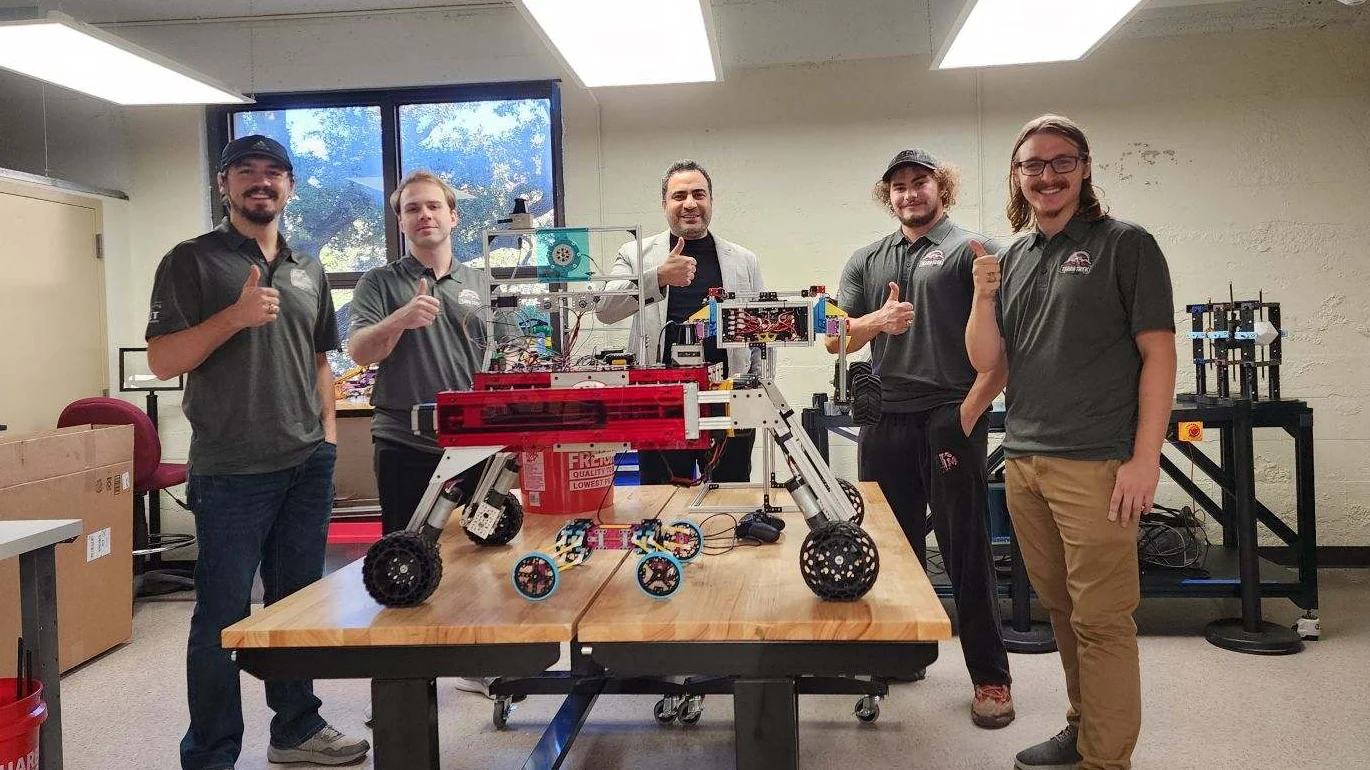
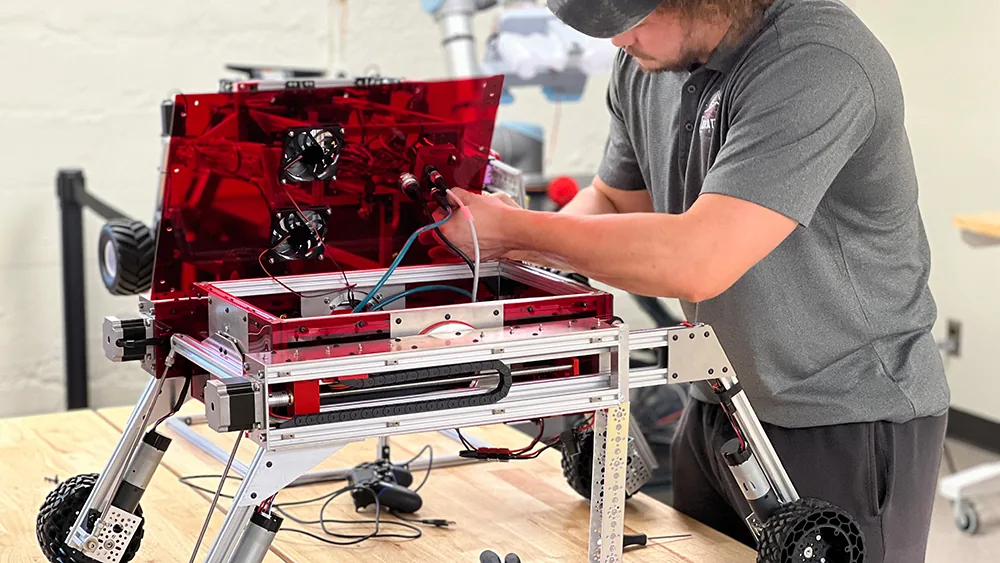
For my capstone, I worked on TerraTrek, a rover combining ROS 2 Jazzy, SICK TiM561 lidar navigation, SLAM Toolbox, and a dynamic rocker-bogie suspension. The gallery follows the earlier open-frame prototype through the later red rover and its suspension tests.
Navigation and suspension
TerraTrek used ROS 2 Jazzy with a SICK TiM561 lidar for navigation and slam_toolbox for SLAM. The dynamic rocker-bogie suspension addressed mobility on low-friction terrain, bringing the navigation work and mechanical development into the same capstone.
Working through the hardware
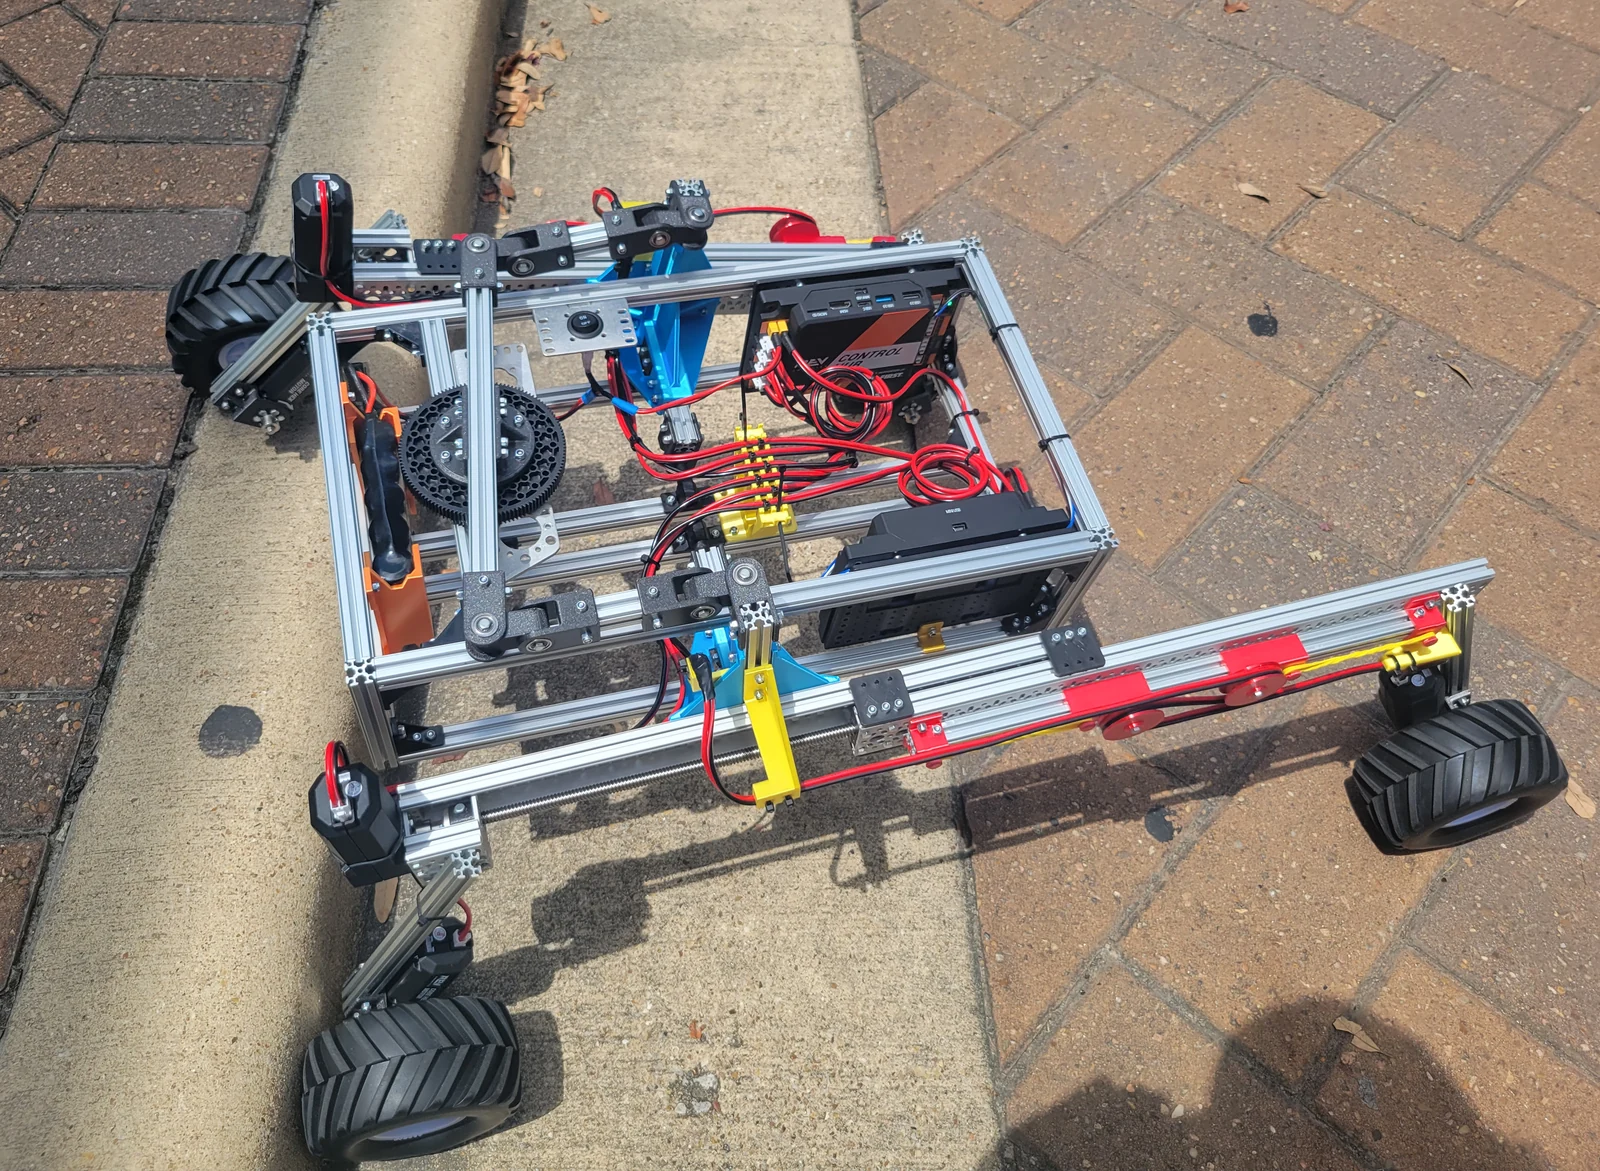
The earlier build left the frame and wiring open. The red rover brought the later chassis and suspension together, with a SICK TiM561 lidar mounted above the body.
Bench and outdoor tests
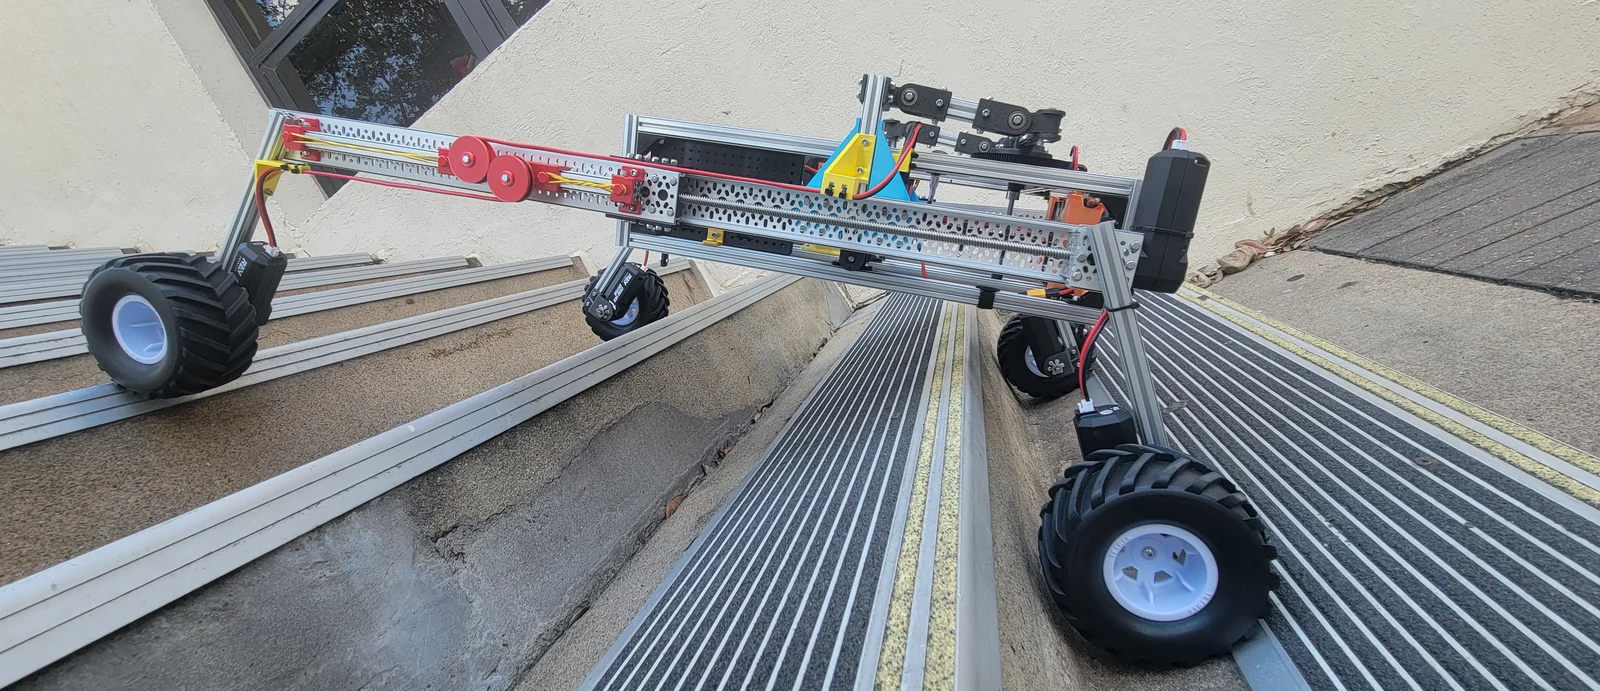
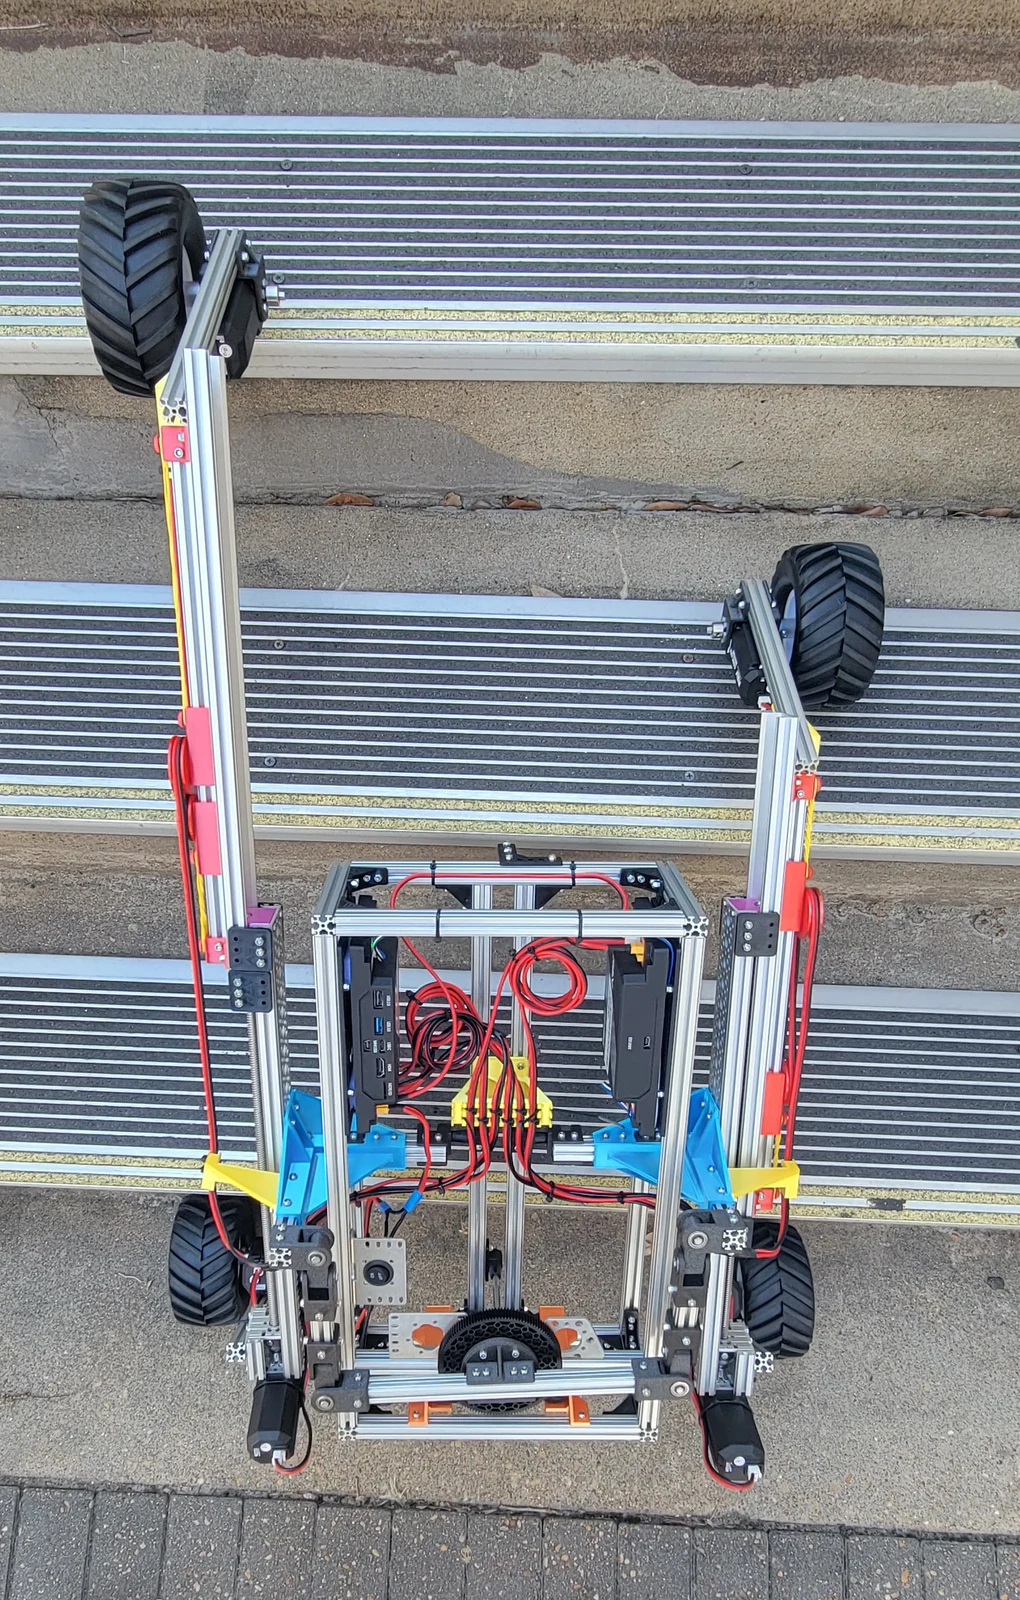
The gallery includes wheel-assembly movement on the bench, an outdoor suspension test, and stair footage from the earlier prototype.
Technical details
- Software: ROS 2 Jazzy with SLAM Toolbox (slam_toolbox).
- Sensing and navigation: SICK TiM561 lidar for navigation.
- Mechanics: Dynamic rocker-bogie suspension.
A closer look