Personal
Homemade BLDC Actuator
I built a hand-wound 36N42P brushless actuator with an AS5047P encoder and a largely printed structure. It was backdrivable, with tunable PID control that could resist externally applied motion when commanded. The gallery follows the motor construction, mechanical packaging, and position-control tests.
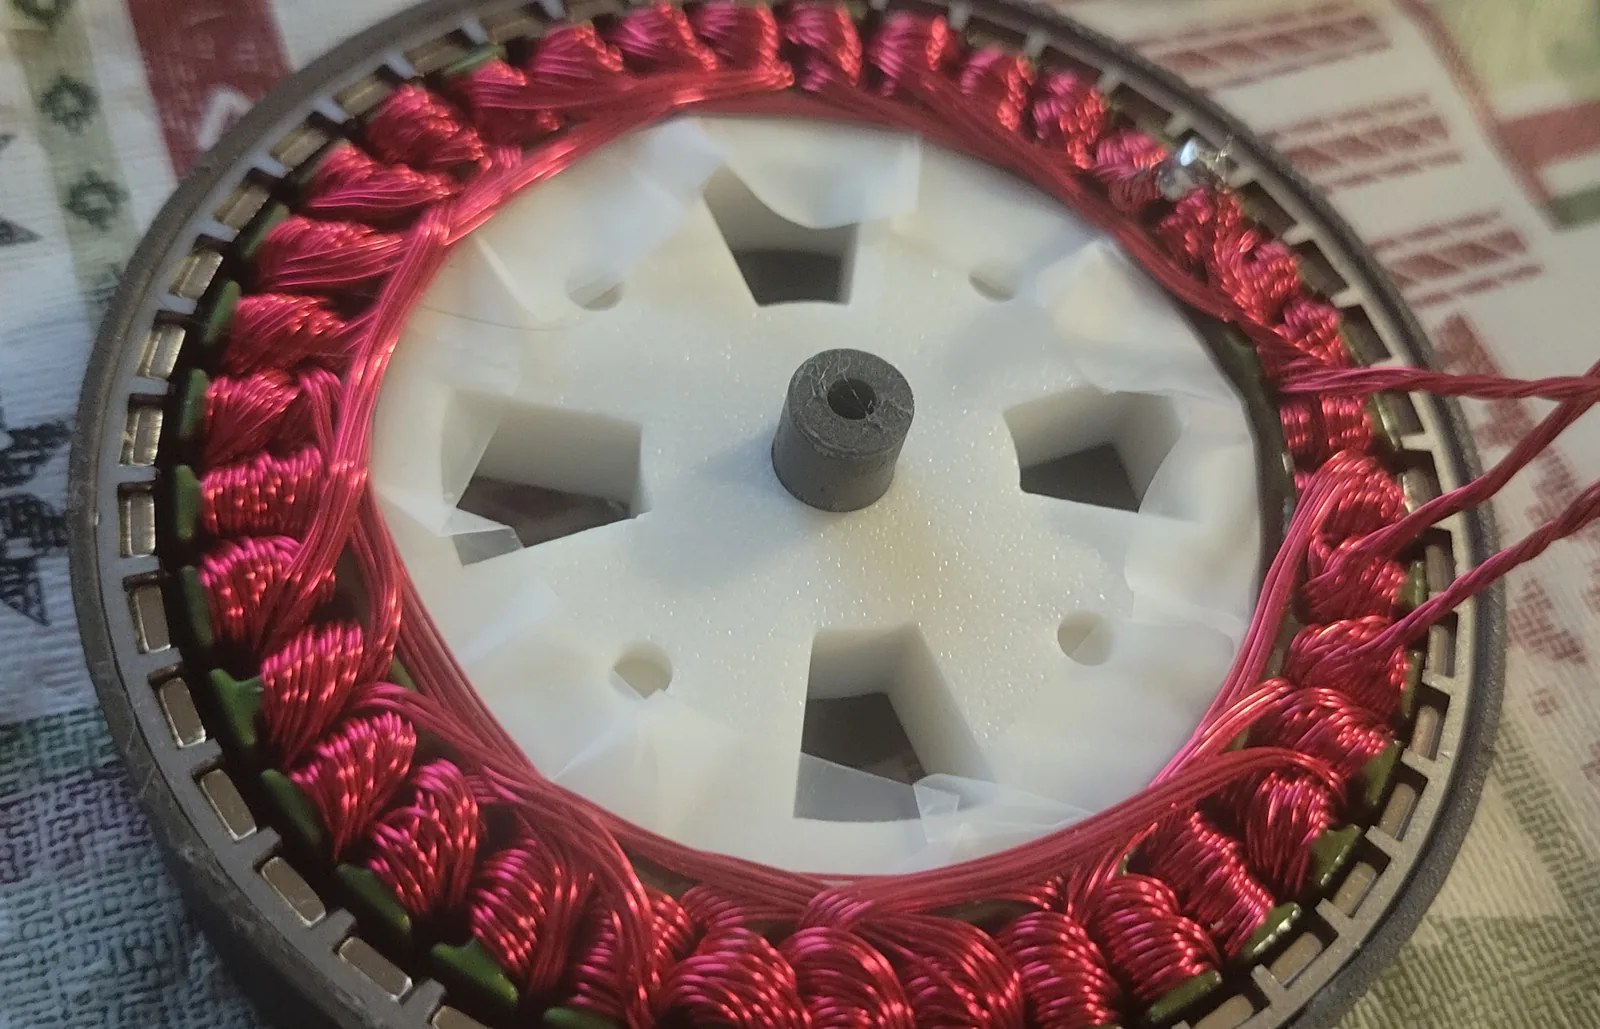
Building the motor
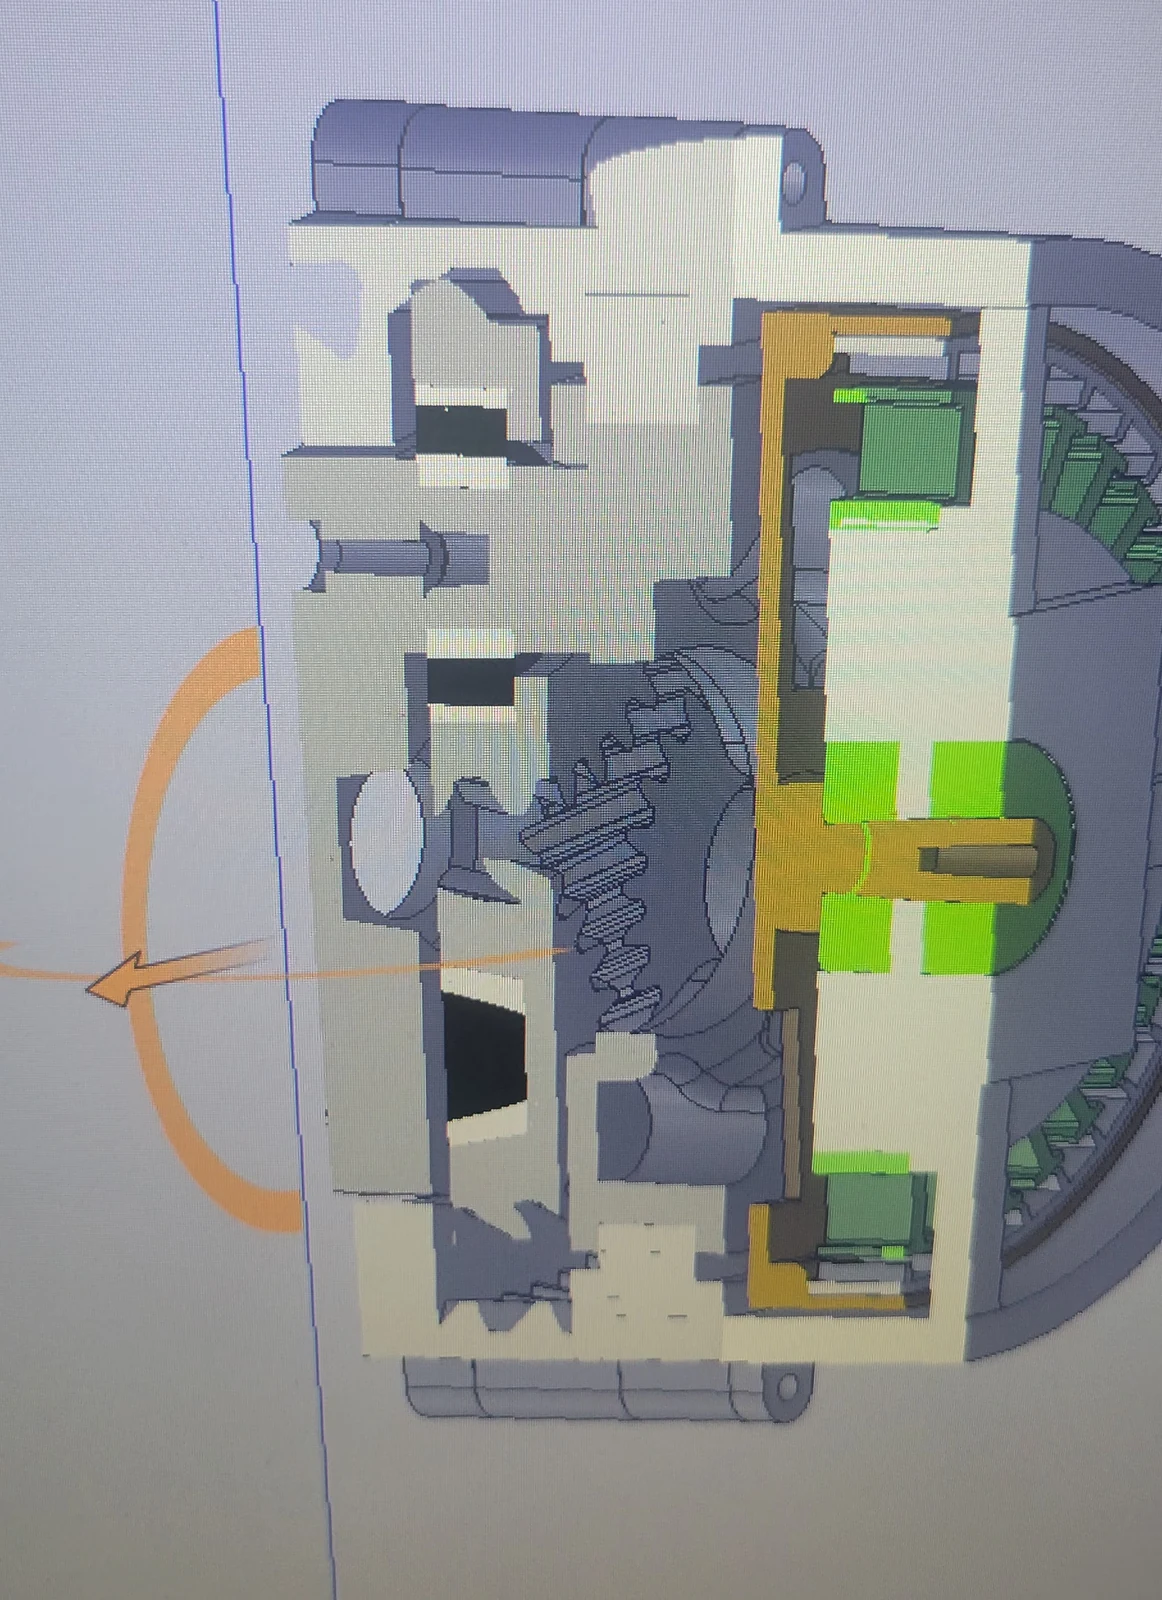
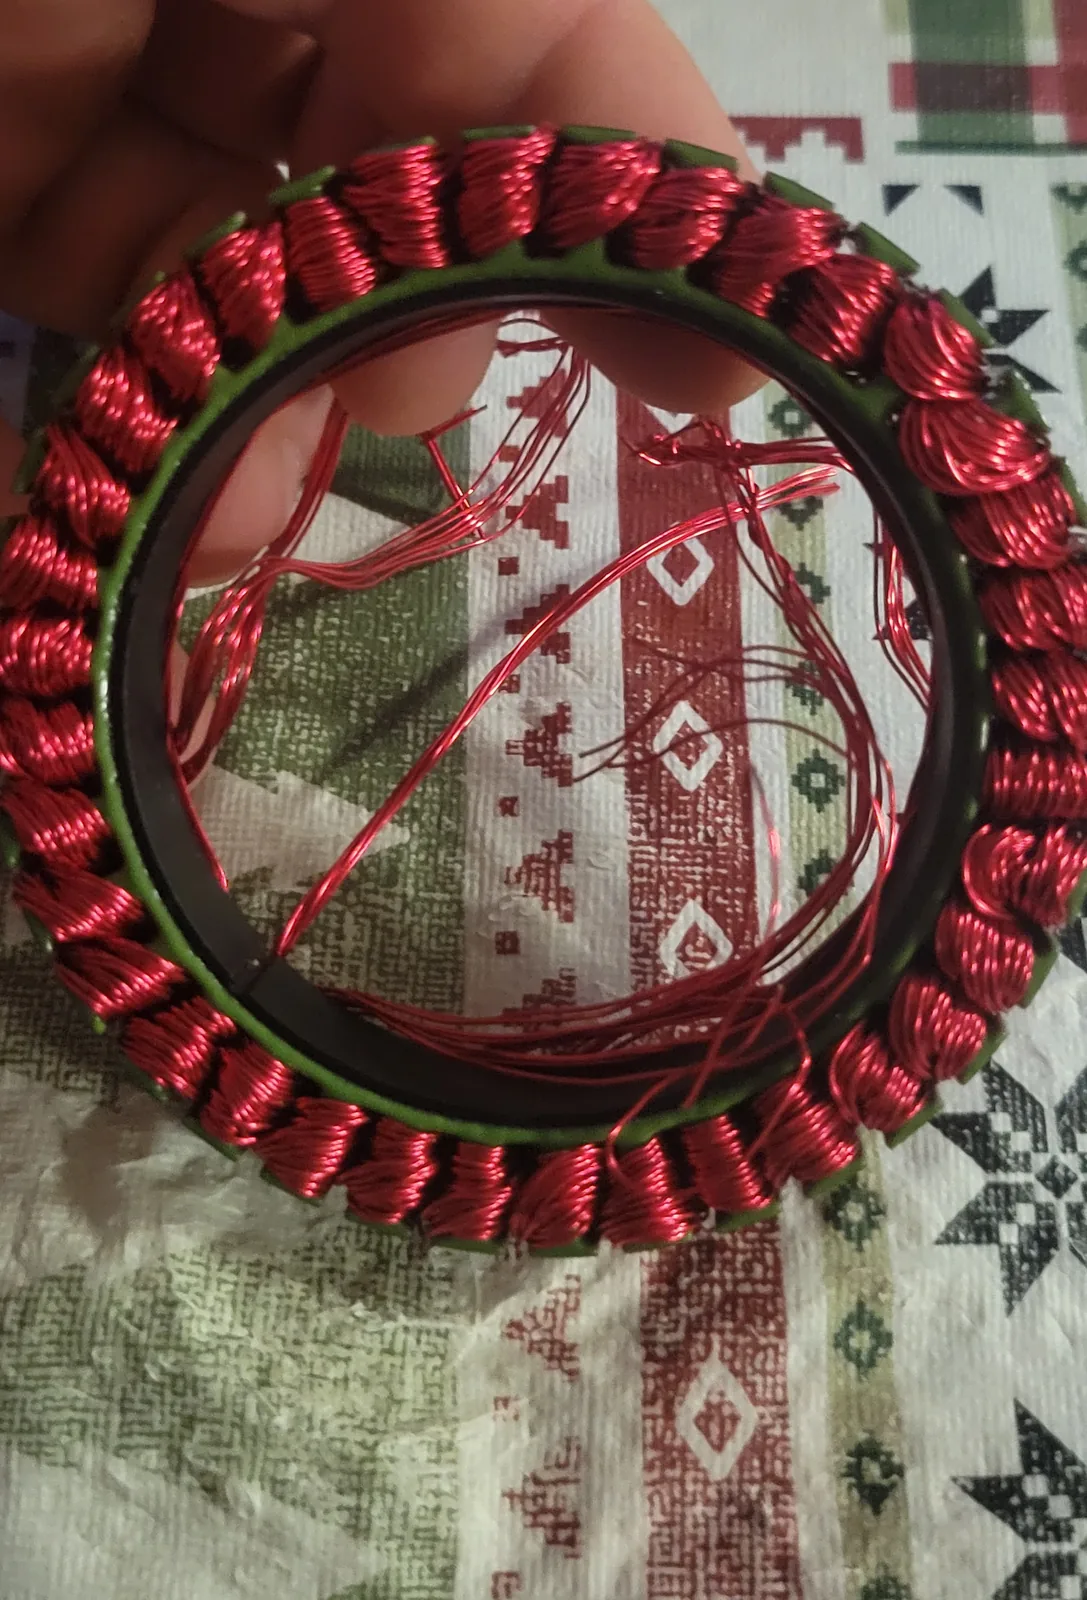
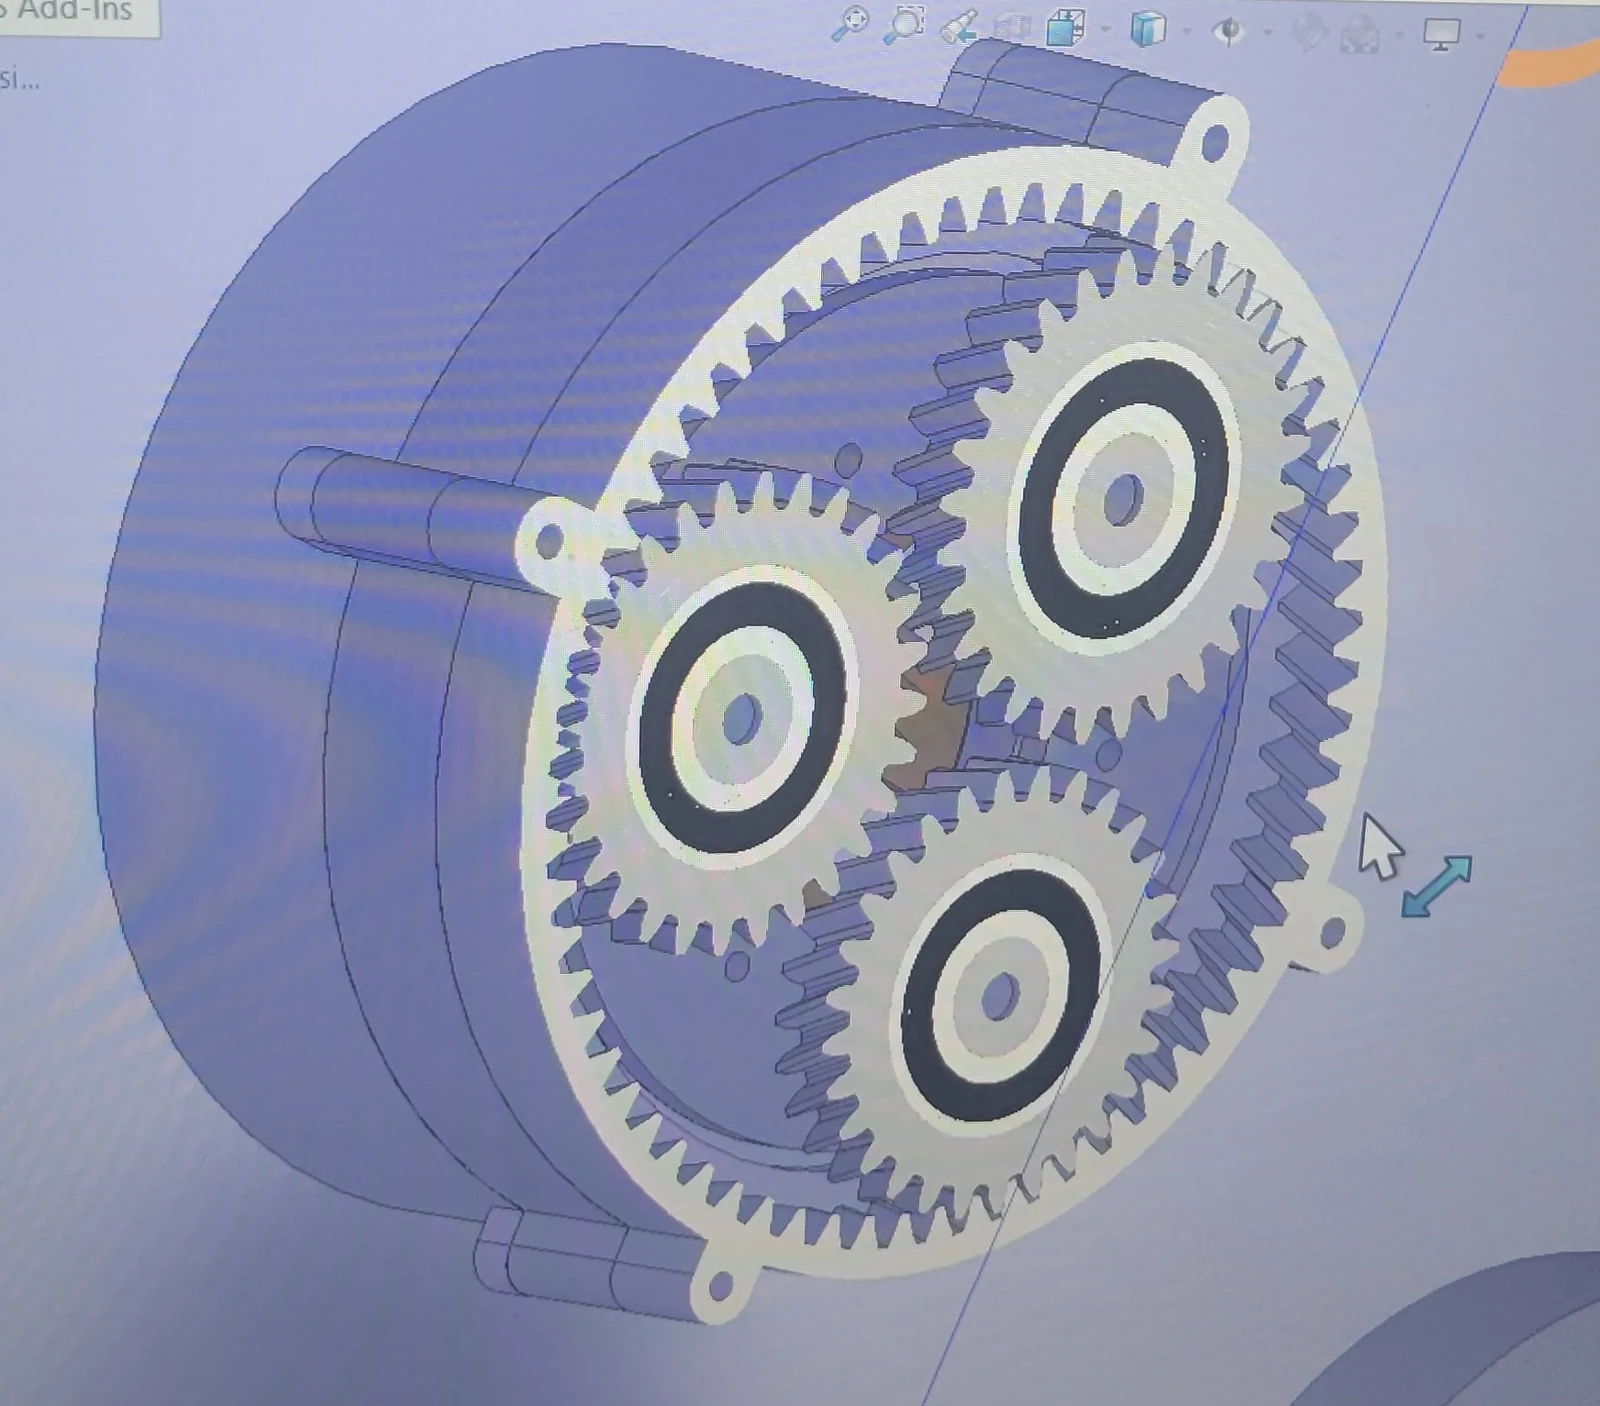
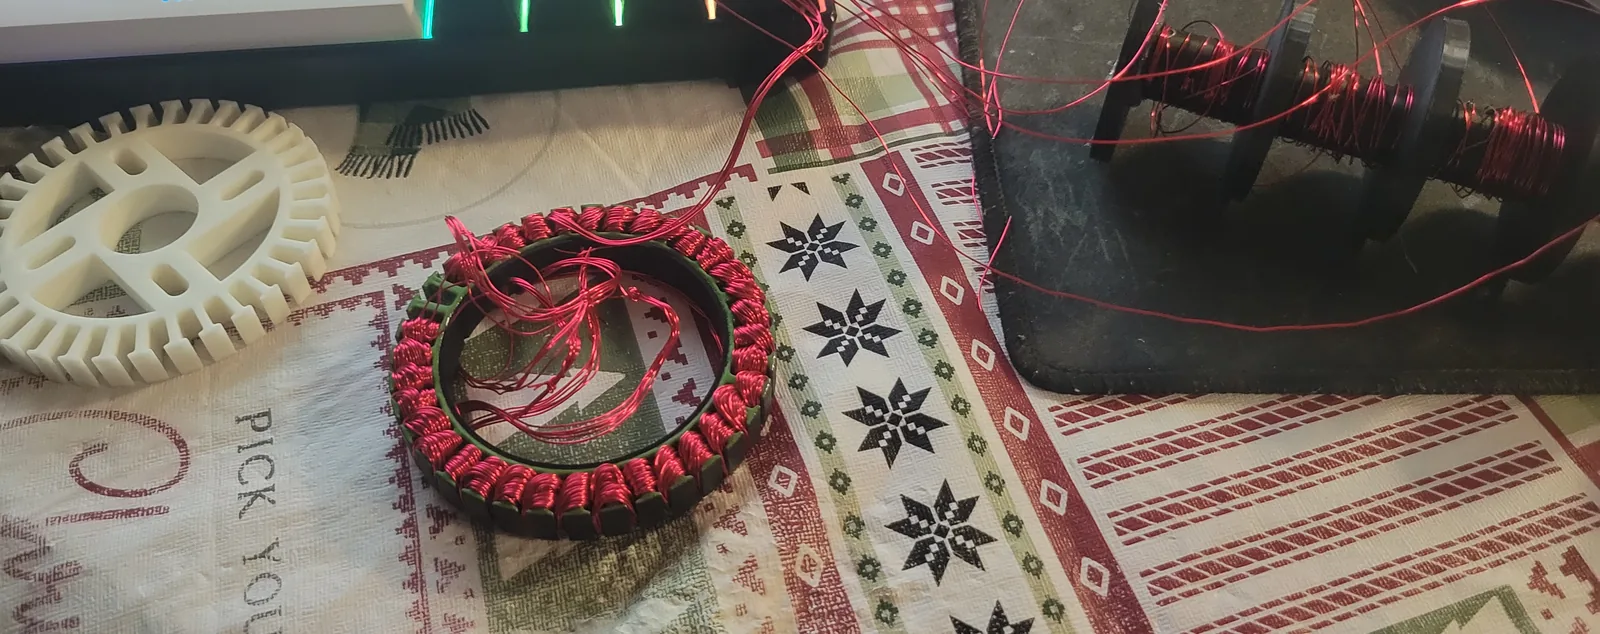
The motor has 36 stator teeth and 42 rotor magnets, written as 36N42P. I hand-wound the stator and printed the rotor carrier, stator mount, and housing, bringing the bearing and reduction stage into the assembly.
Feedback and control
An AS5047P magnetic rotary encoder provided position feedback. I could backdrive the actuator and adjust its PID gains to change the positional response, including resistance to motion when commanded.
Technical details
- Motor layout: 36N42P — 36 stator teeth and 42 rotor magnets/poles.
- Position feedback: AS5047P magnetic rotary encoder.
- Control behavior: Backdrivable, with tunable position-control PID gains and commanded resistance to motion.
- Construction: Hand-wound stator, printed structural parts, integrated bearing and reduction stage.
A closer look