Academic
UR3 Robot Vision Sorter
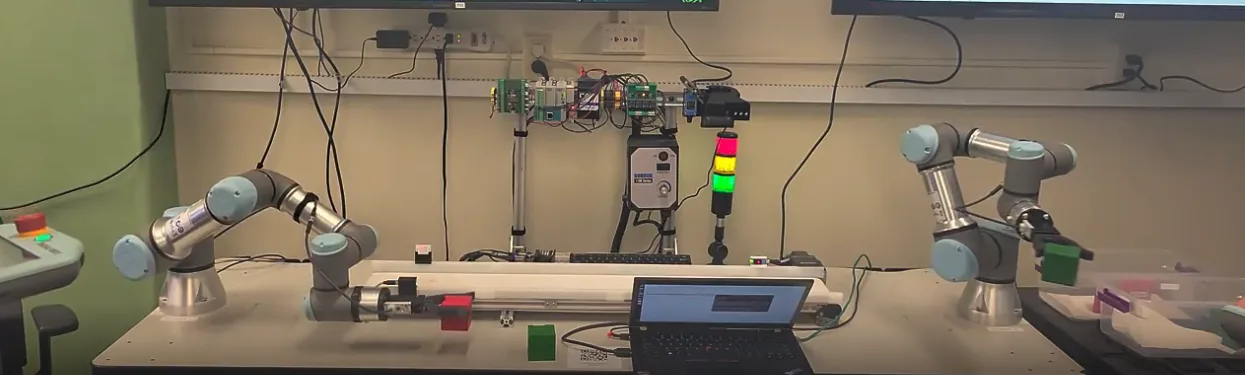
I worked on an academic sorting cell using UR3 arms, a conveyor, and RGB cameras. OpenCV detected the cubes by color and located each cube’s centroid to help align the gripper for pick-and-place motion.
Finding the center of a cube
OpenCV processed the RGB-camera images for basic cube-color detection. The detected centroid gave a position reference for aligning the gripper over the cube.
From vision to handling
The bench combined two UR3 arms, the conveyor, camera hardware, and a control station. PolyScope programming handled the robot motion within the sorting workflow.
Technical details
- Vision software: OpenCV for cube-color detection and centroid position.
- Vision hardware: RGB cameras.
- Robot cell: Two UR3 arms, a conveyor, and PolyScope robot programming.