Team
SpiderBot
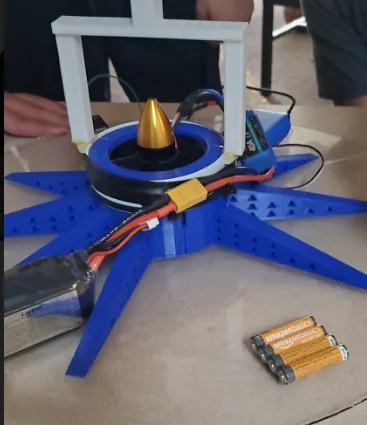
Our Turtle Robotics team explored whether fan-driven suction could hold a robot against a wall for travel. I designed the test rig, using Bernoulli’s principle as a starting point for investigating the adhesion force available at different fan speeds.
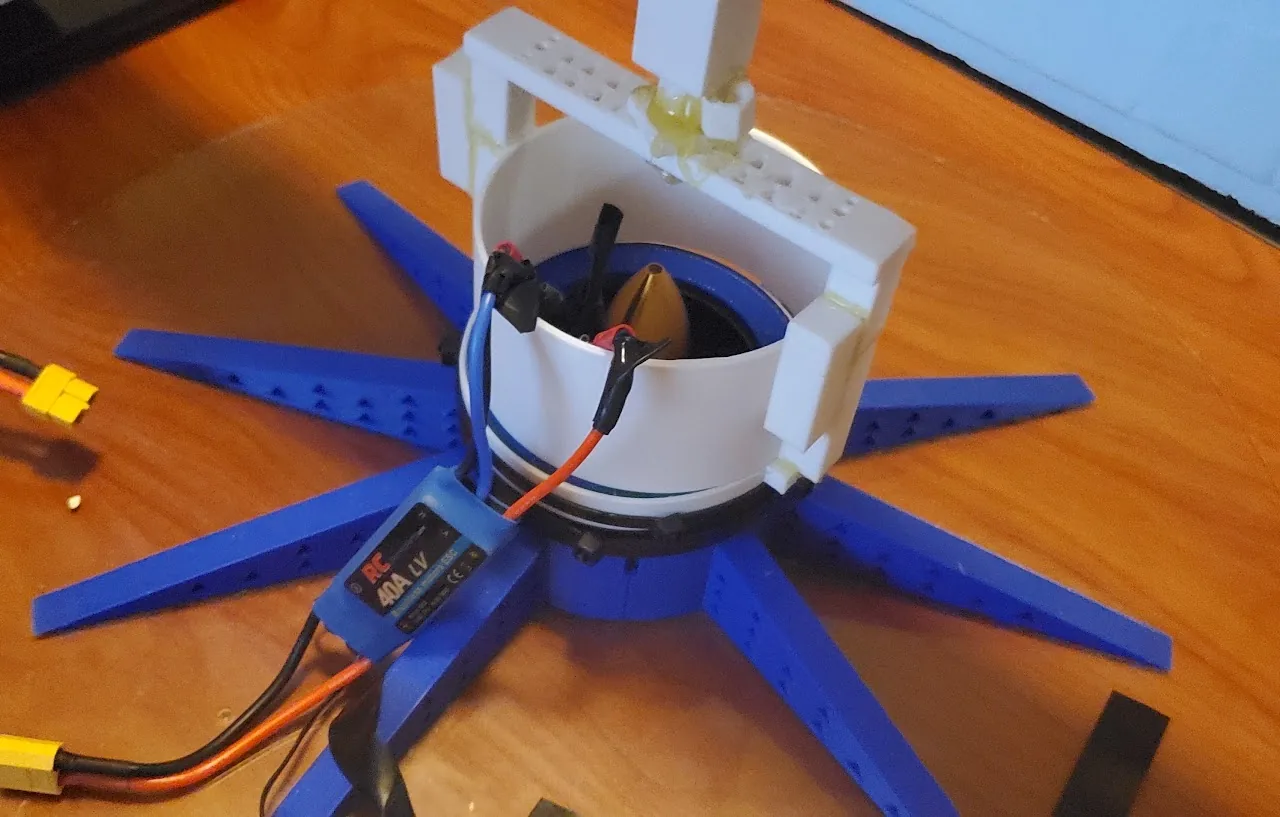
From airflow to adhesion
The idea was to use airflow and the resulting pressure difference to create force toward the surface. We wanted to find out whether that force could support the proposed wall-travel concept.
Testing the force
My rig investigated the downward pull in the test setup, expressed in newtons, at different fan speeds. We also explored the gap height. The photos document the test assembly used to evaluate the concept.
Technical details
- Physical principle: Fan-driven airflow and pressure difference, informed by Bernoulli’s principle.
- Test variables: Fan speed and gap height.
- Test quantity: Pull force in newtons in the downward-facing test arrangement.
A closer look