Academic
SCUTTLE Collector / Dog V2
I used the open SCUTTLE robotics platform developed at Texas A&M as the foundation for a golf-ball collector. My work involved camera and lidar inputs, object detection, and navigation. We called the robot Dog V2; it is separate from the Dog V3 quadruped.
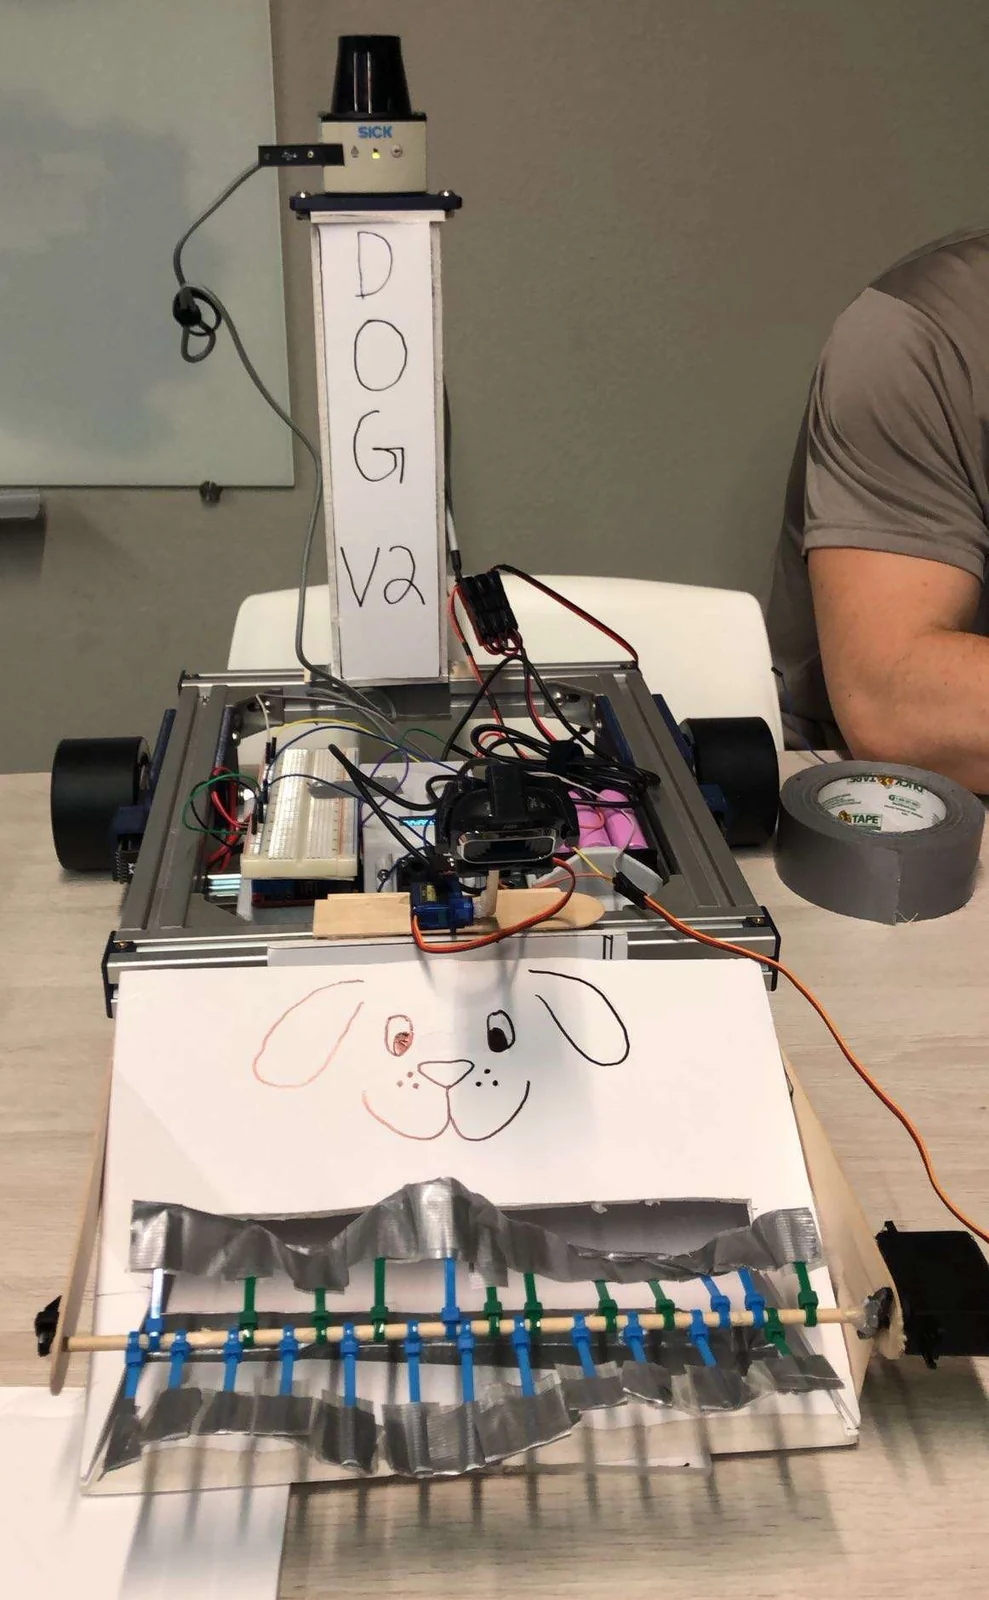
Starting from SCUTTLE
The project built on the existing SCUTTLE teaching platform and its shared hardware/software infrastructure. That provided a foundation for the collector and its sensing and motion work.
Finding and approaching a ball
I worked on using the camera and lidar for golf-ball detection, navigation, and collision avoidance. The robot carried a front collection mechanism and a raised SICK TiM561 lidar; the floor clip shows it driving and turning near a ball.
Technical details
- Foundation: Texas A&M-origin SCUTTLE open robotics platform.
- Sensor inputs: Camera and SICK TiM561 lidar.
- Project work: Golf-ball detection, navigation, and a front collection mechanism.