Personal
Earlier Actuator Designs
My earlier actuator designs explored NEMA 17 or NEMA 23 stepper motors driving 9:1 planetary gearboxes. I used TB6600 stepper drivers and rear-mounted AS5600 shaft encoders. The surviving footage shows the assemblies moving a long test arm on the bench.
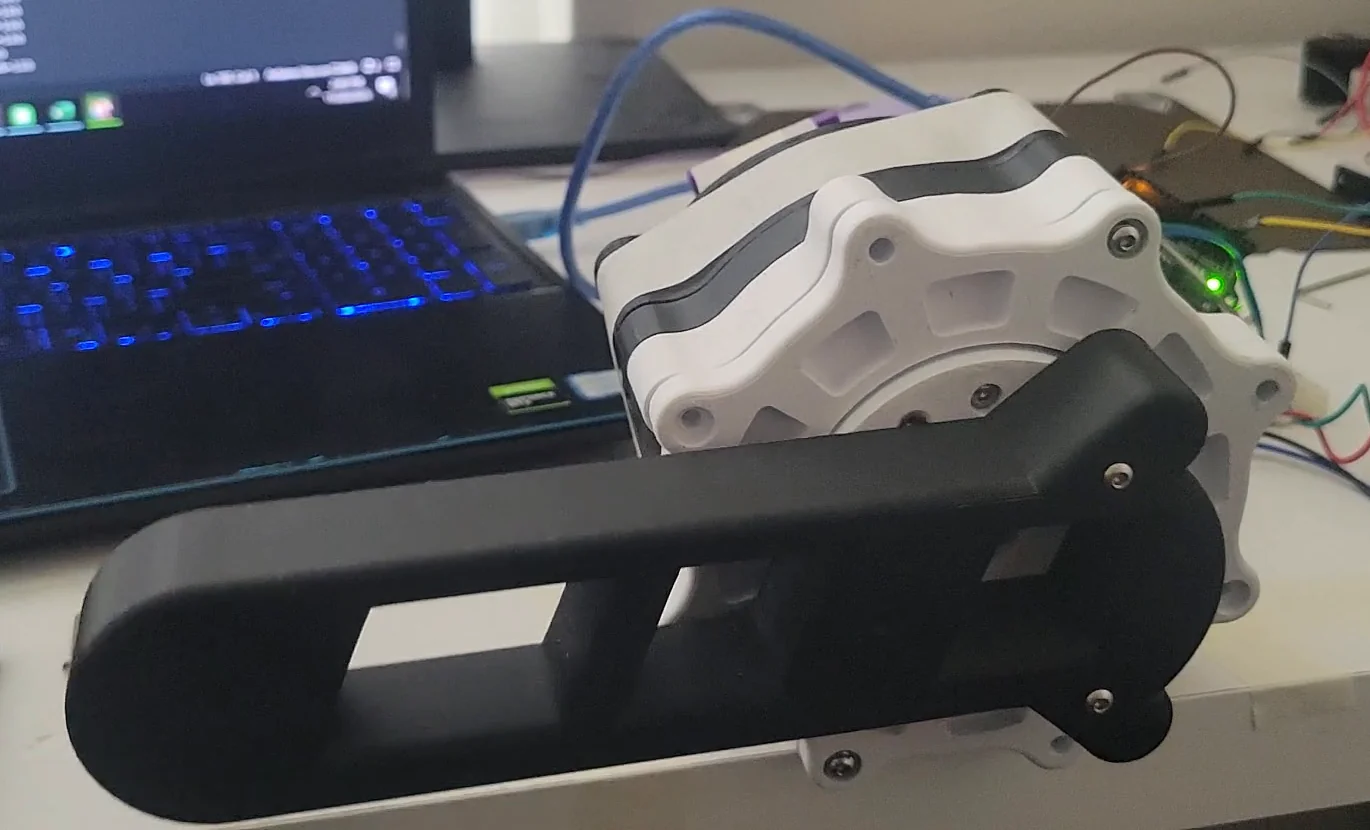
Stepper-driven prototypes
These designs paired a stepper input motor with a planetary reduction stage. The motor and gearbox were assembled into a prototype actuator, with an AS5600 encoder mounted behind the stepper.
On the test bench
The white housing and black test arm show one of the earlier assemblies. The close-up and wider clips show the arm moving through different positions.
Technical details
- Input motors: NEMA 17 or NEMA 23 stepper motors across the earlier designs.
- Reduction: 9:1 planetary gearbox.
- Motor drivers: TB6600 stepper drivers.
- Feedback hardware: AS5600 shaft encoder mounted behind the stepper.