Personal · Work in progress
ArUco Localization & Robot Swarm
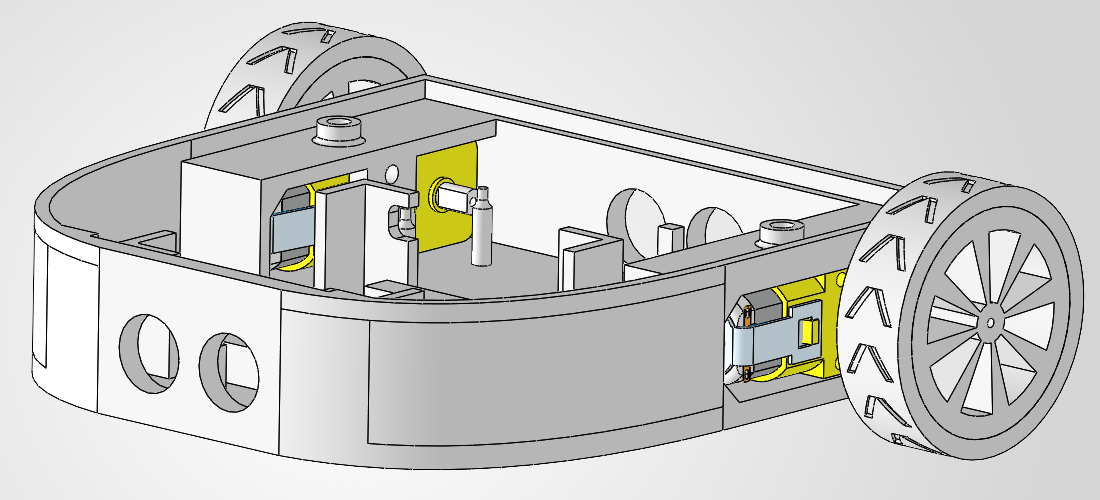
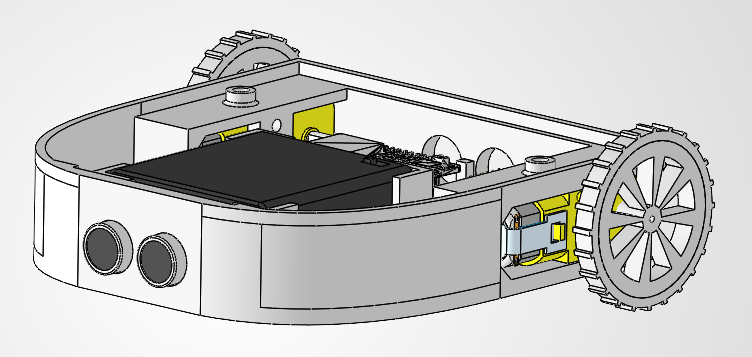
I'm testing three small mobile robots with ArUco position tracking and swarm control. The clips show formation driving, repositioning, column form-up, and individual driving. Two CAD views show how the chassis changed during the build.
Three robots on the floor
I’m testing formation driving, repositioning, and individual control. The first clip shows the robots moving together; the gallery includes the other tests and a view of the control dashboard.
Chassis development
The two CAD views show the first chassis design and an updated version. They document the mechanical changes alongside the current driving tests.
Technical details
- Hardware: Three small wheeled robots; two chassis CAD revisions are shown.
- Position tracking: ArUco visual markers and camera overlays in the demo footage.
- Tests shown: Formation driving, repositioning, column form-up, individual driving, and the control dashboard.
A closer look