Personal
Dog V3
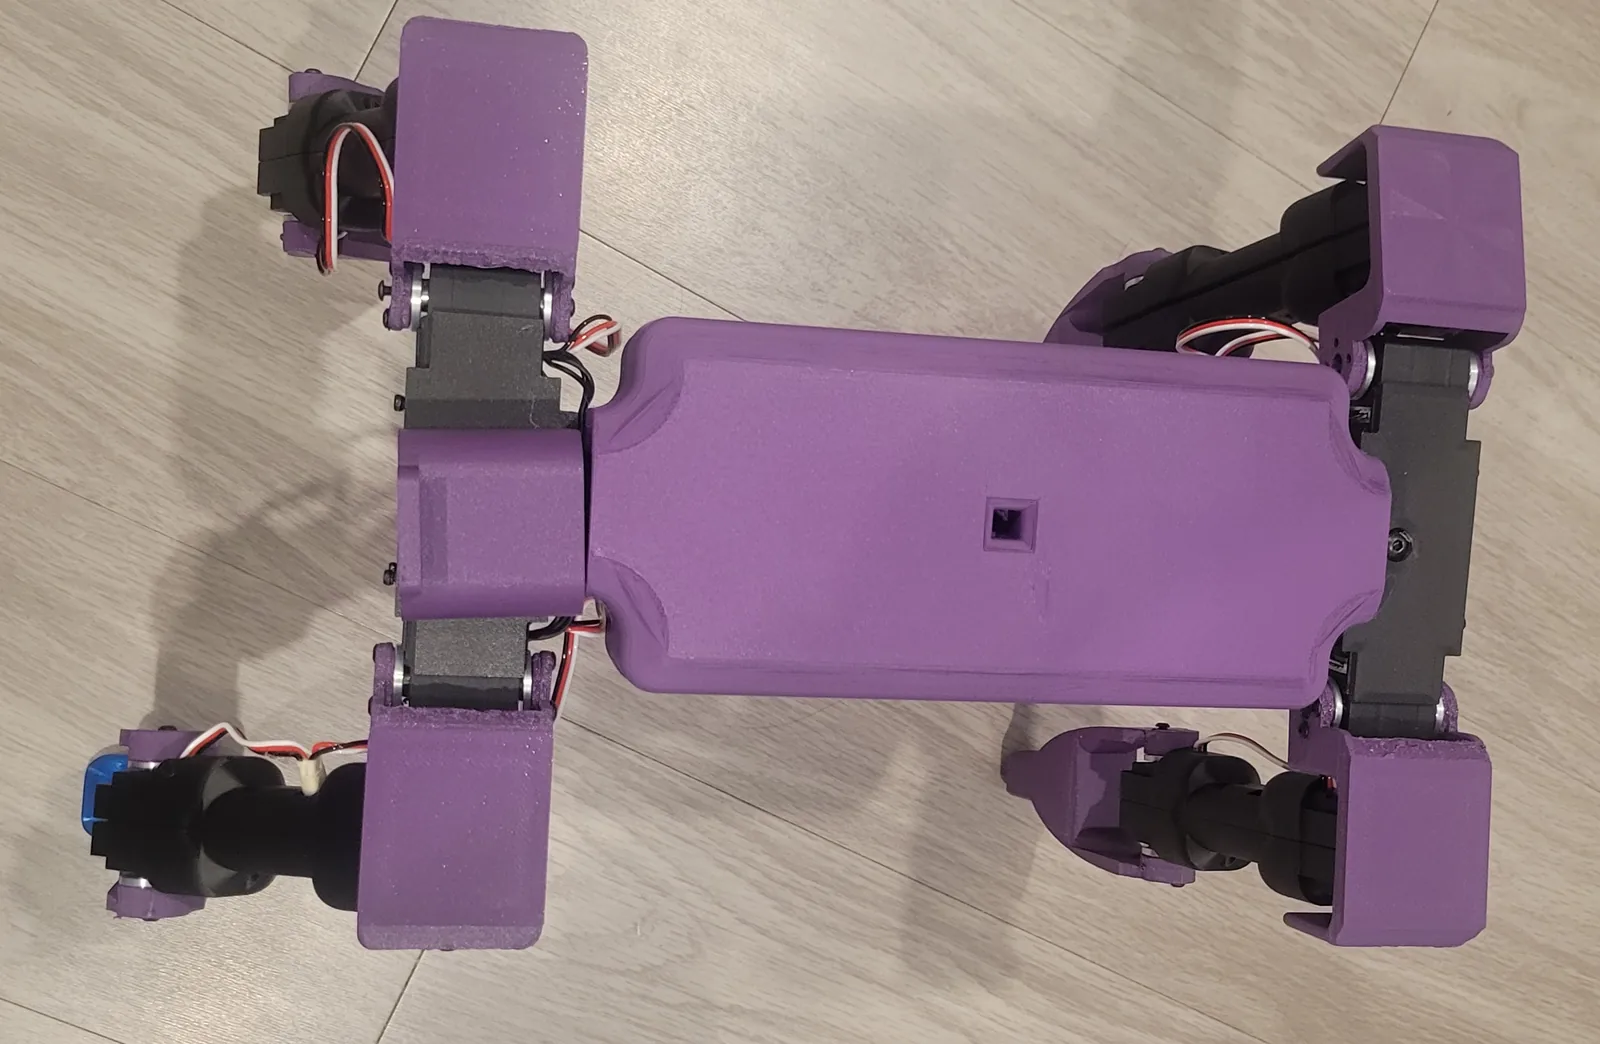
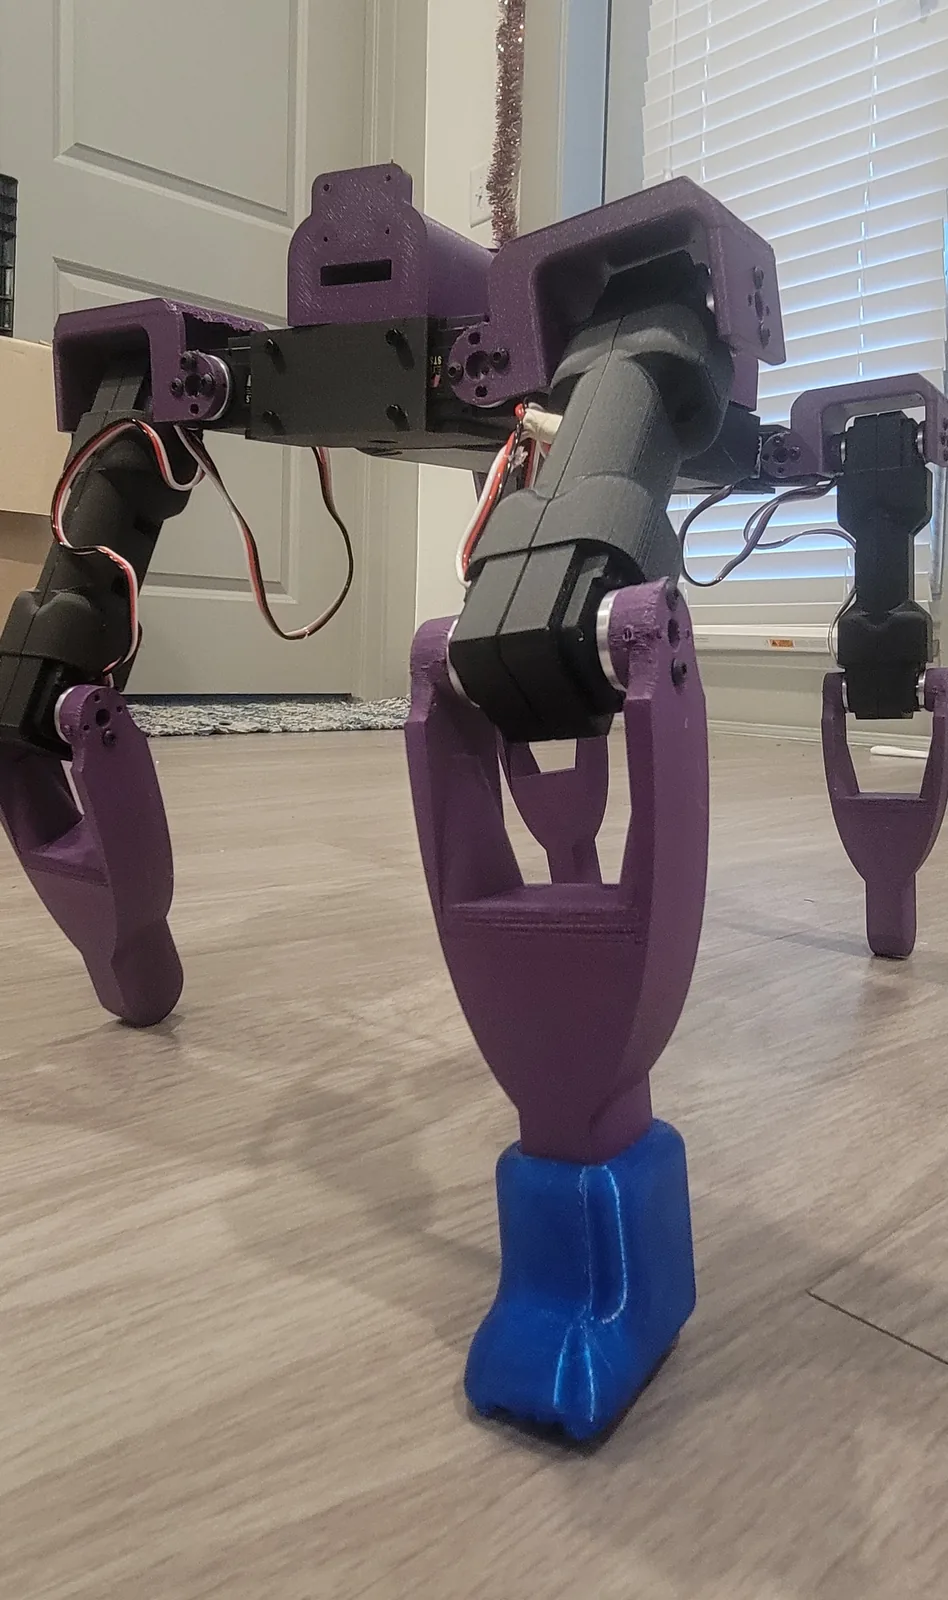
I built Dog V3 around a printed chassis, articulated legs, and a serial servo bus. The work spans SolidWorks design, electronics packaging, and gait tuning. The purple revision is shown walking; the earlier footage documents the prototypes that came before it.
Built to come apart
I printed the body in sections and bolted it around the electronics. That lets me open the chassis without dismantling the whole robot. The legs use segmented structures with an actuator at each joint.
Getting the legs together
The early work happened with the robot supported on a stand: leg motion, kinematic checks, and timing. Floor testing came next. I rebuilt the body and legs as the tests showed what needed to change.
A walking revision
The later purple build has a revised body and a newly tuned gait. The gallery follows that revision back to the earlier floor and standing tests, with the wiring still exposed.
An early prototype
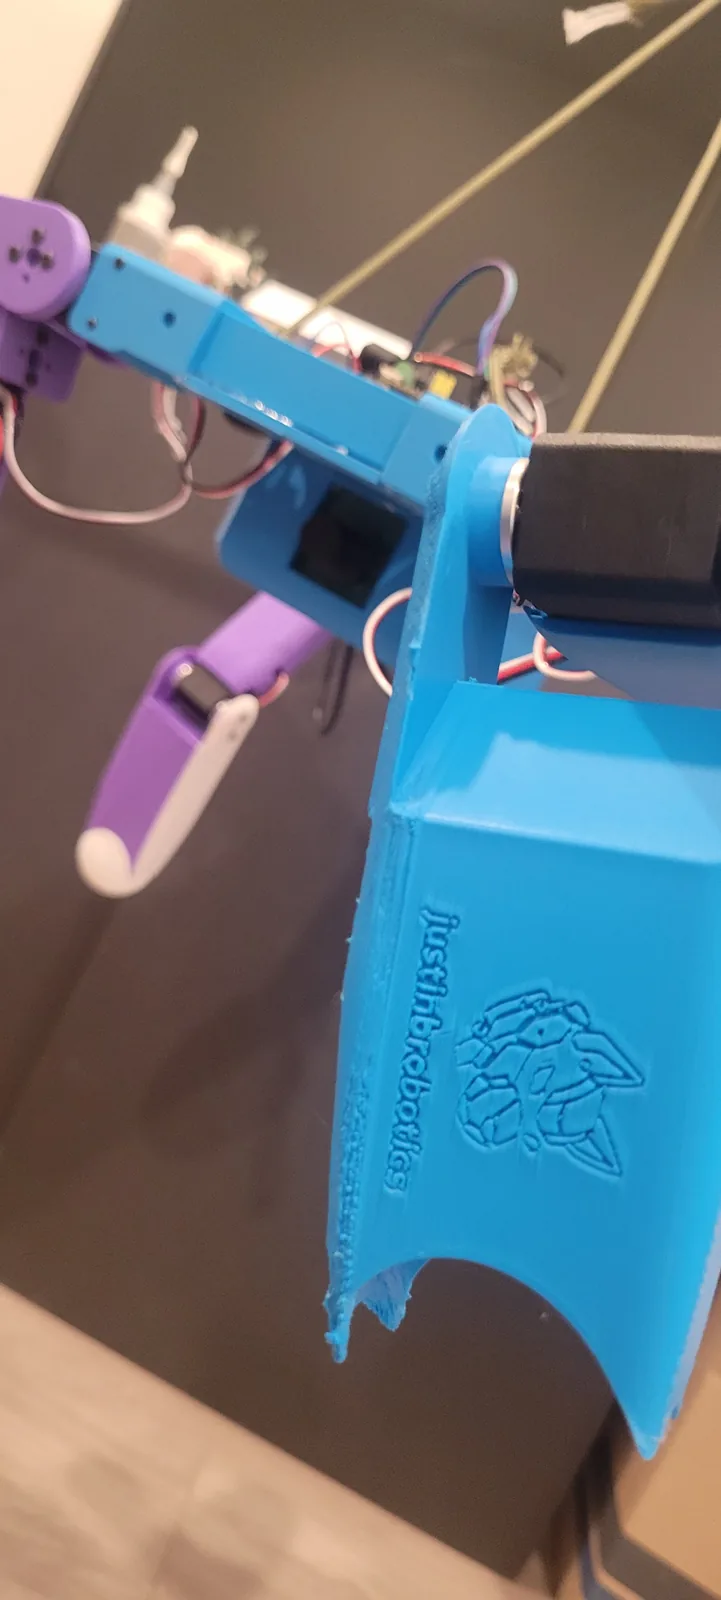
I tested an early leg prototype on a stand. The white mechanism in this clip is part of that earlier work.
Technical details
- Actuation: STS3215 12 V servos on a serial servo bus.
- Communications: Raspberry Pi 3 Model B+.
- Motion processing: ESP32 handles kinematics, trajectories, and path planning.
- Control software: Mainly Python, with a controller GUI for arming.
A closer look